System Architecture
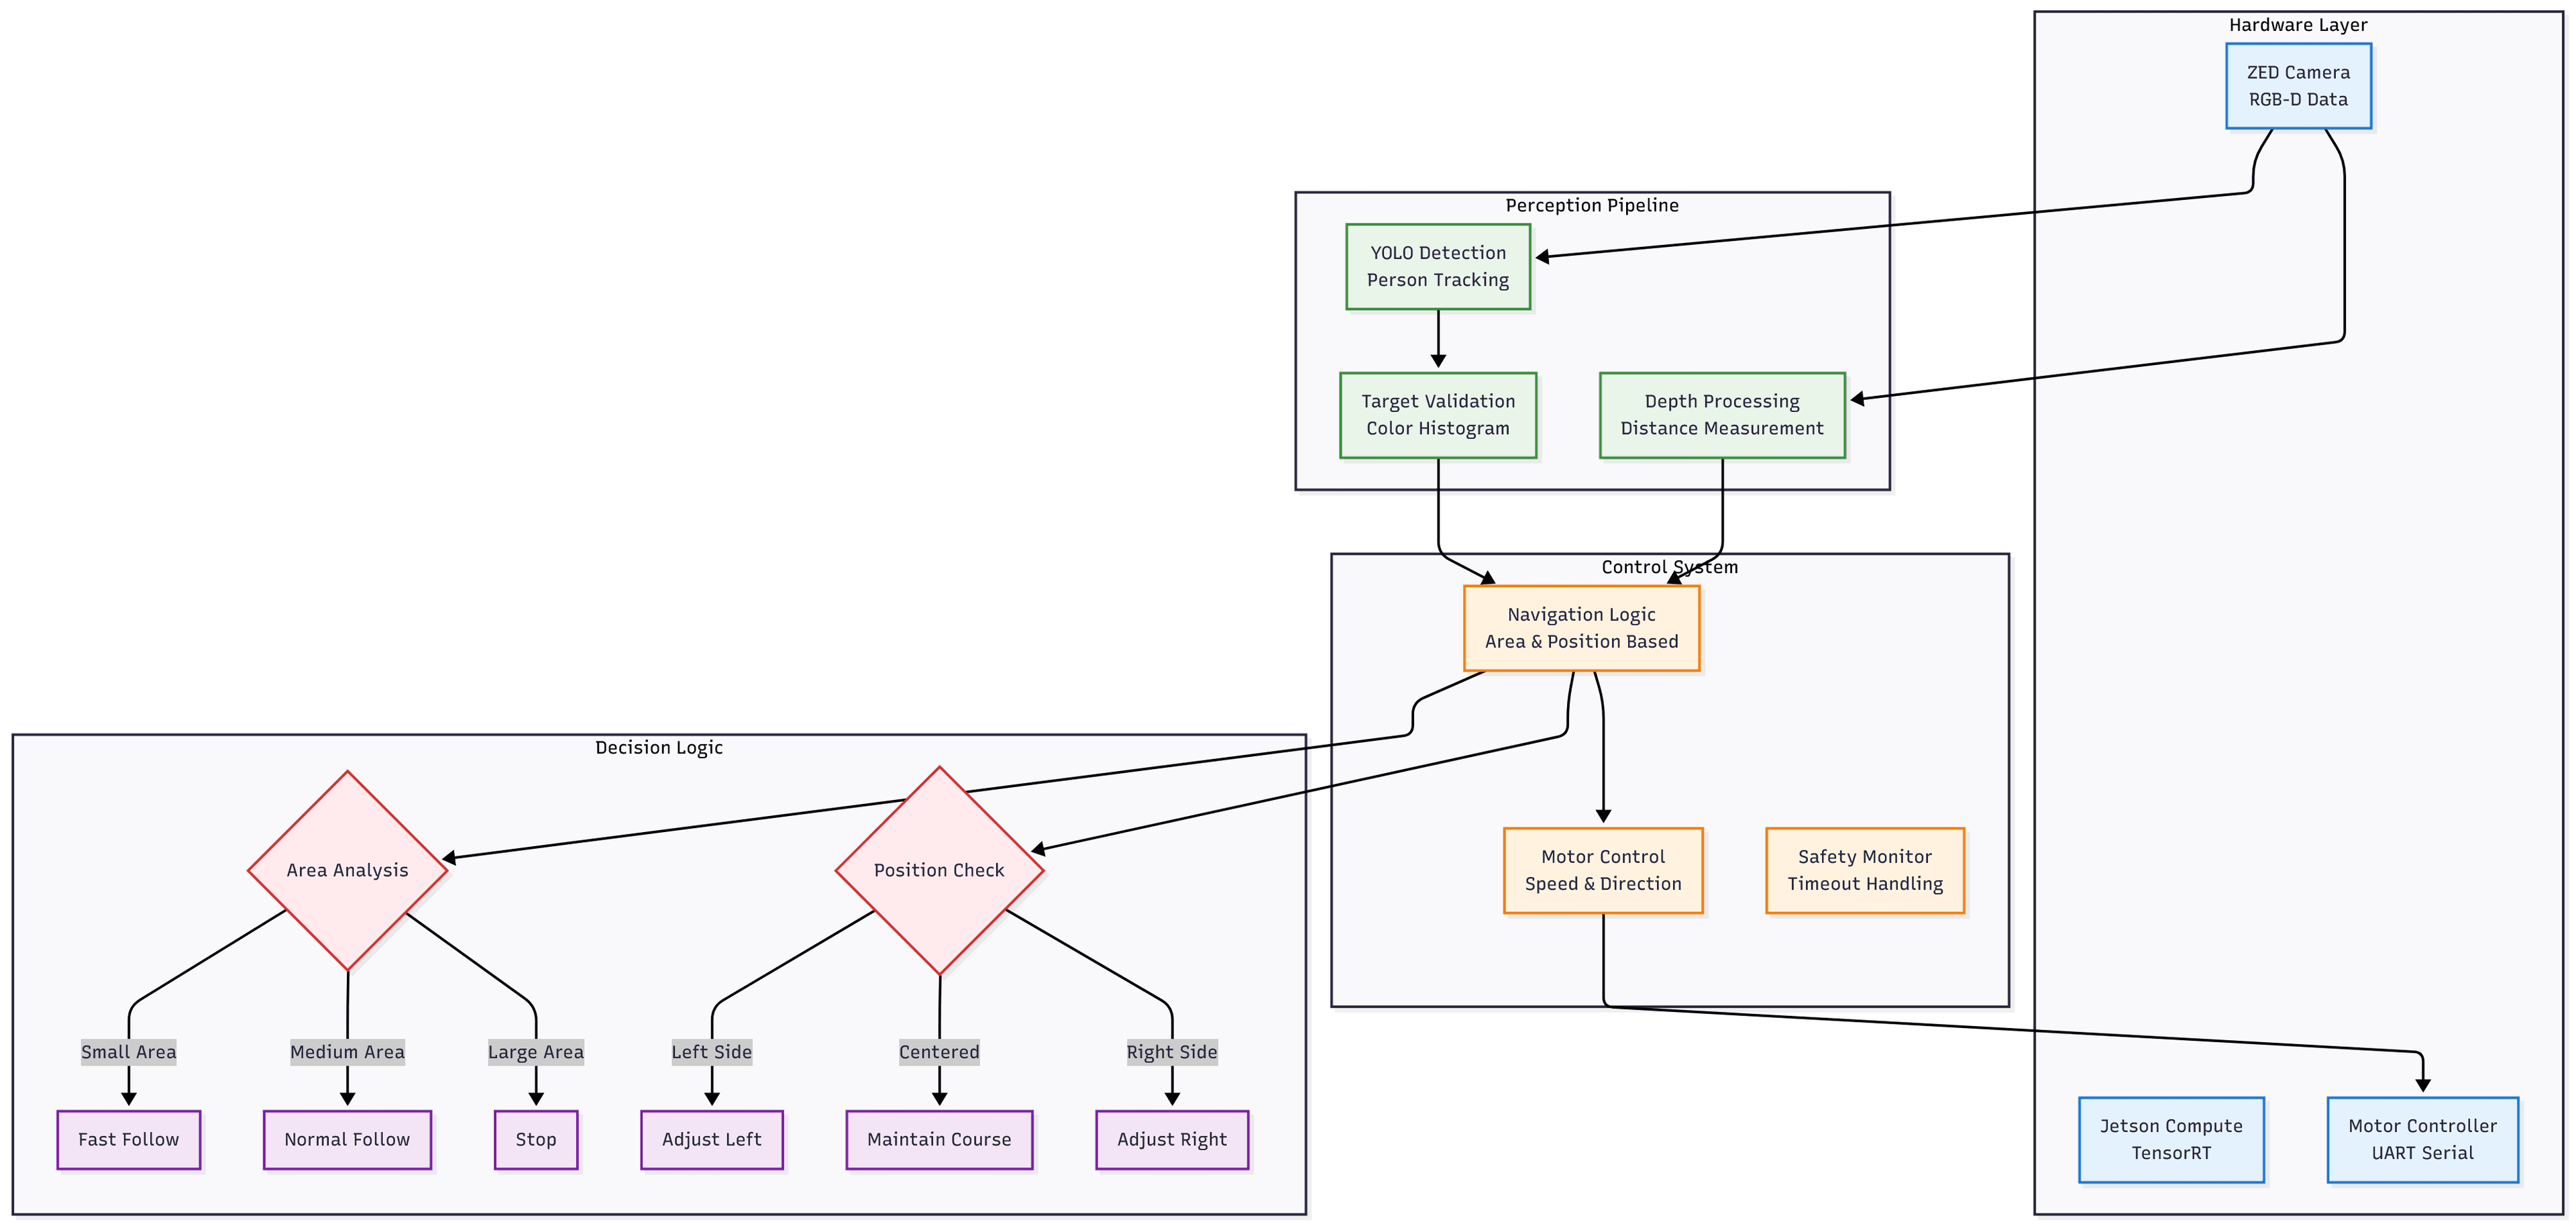
Click to enlarge • Scroll to zoom • Drag to pan • Double-click to reset
Project Overview
Description
Person-following robot built on a Jetson Nano platform with ZED stereo camera for real-time tracking. The system uses YOLOv11 for person detection and implements color histogram matching in HSV space to maintain target consistency across frames, preventing target switching when multiple people are present.
Key Features
✓
YOLOv11-based person detection with confidence thresholding and persistent tracking✓
HSV color histogram matching (Bhattacharyya distance) to prevent target switching in multi-person scenarios✓
Three-tier adaptive speed control based on bounding box area thresholds (20k, 50k pixels)✓
Proportional steering correction using frame-center displacement calculations✓
Depth validation filtering with 1000mm tolerance to reject false positives✓
Multi-threaded architecture with dedicated camera capture thread for consistent 30-40ms frame processing✓
Automatic recalibration every 120 frames to adapt to lighting and distance changesTechnology Stack
Jetson NanoZED Stereo CameraOpenCVYOLOv11PythonPySerial
Project Links
© 2025 Charlotte Burns